Un corpo è in equilibrio statico quando sta fermo e continua a restare fermo nel tempo. Capire quando questo accade è il primo passo verso lo studio delle forze: se sappiamo scrivere le condizioni che tengono un corpo immobile, sappiamo anche prevedere quando invece comincerà a muoversi. Questa sezione parte dal caso più semplice, il punto materiale, per poi estendere il discorso al corpo rigido, dove non basta più annullare le forze ma occorre annullare anche i momenti. Le leve sono il caso quotidiano di quell’equilibrio rotazionale.
A body is in static equilibrium when it is at rest and remains at rest over time. Understanding when this happens is the first step towards the study of forces: if we can write the conditions that keep a body still, we can also predict when it will instead start to move. This section starts from the simplest case, the point mass, and then extends the discussion to the rigid body, where it is no longer enough to cancel the forces, but the moments must be cancelled too. Levers are the everyday case of that rotational equilibrium.
Un corpo è in equilibrio statico se sta fermo e continua a stare fermo nel tempo. Per un punto materiale — un oggetto così piccolo da poterne trascurare le dimensioni e la forma — questa condizione si traduce in un requisito semplicissimo sulle forze che agiscono su di esso: la loro risultante deve essere nulla. Se in una qualsiasi direzione le forze non si compensassero, il punto comincerebbe ad accelerare in quel verso e l’equilibrio sarebbe rotto.
Principio — Condizione di equilibrio per un punto materiale
La somma vettoriale di tutte le forze agenti sul punto deve essere nulla.
Trattandosi di un’uguaglianza fra vettori, essa equivale a più uguaglianze scalari, una per ogni direzione dello spazio. Lavorando nel piano, la condizione si spezza in due equazioni indipendenti:
cioè la somma di tutte le componenti orizzontali è zero e la somma di tutte le componenti verticali è zero. Ogni forza va prima scomposta lungo gli assi scelti, poi si sommano separatamente le componenti e le componenti . Scegliere assi comodi — spesso uno lungo la direzione di una forza nota — semplifica moltissimo i conti.
Regola delle incognite
Se in un problema compaiono incognite (forze, angoli, lunghezze di molle, reazioni vincolari…), per determinarle tutte servono almeno equazioni diverse e non banali: una relazione del tipo non conta. Quando le due condizioni non bastano, la terza equazione arriva quasi sempre da una relazione geometrica del disegno: lunghezze di molle che sommano a una distanza fissa, angoli complementari, corde che passano per pulegge. In molti problemi è letteralmente impossibile arrivare alla soluzione senza leggere la geometria della figura.

Collegamenti
Argomenti: Statica ed equilibrio Concetti: Equilibrio statico Oggetti: Molla
Esercizi collegati: Esercizio svolto — Blocco appeso a due funi · Esercizio svolto — Il Gorilla tira una cassa · Esercizio svolto — Scatola con molla: zona di equilibrio
A body is in static equilibrium if it is at rest and remains at rest over time. For a point mass — an object so small that its dimensions and shape can be neglected — this condition translates into a very simple requirement on the forces acting on it: their resultant must be zero. If in any direction the forces failed to cancel, the point would begin to accelerate that way and the equilibrium would be broken.
Principle — Equilibrium condition for a point mass
The vector sum of all forces acting on the point must be zero.
Being an equality between vectors, it is equivalent to several scalar equalities, one for each direction in space. Working in the plane, the condition splits into two independent equations:
that is, the sum of all horizontal components is zero and the sum of all vertical components is zero. Each force must first be resolved along the chosen axes, then the components and the components are summed separately. Choosing convenient axes — often one along the direction of a known force — greatly simplifies the working.
Rule of unknowns
If a problem contains unknowns (forces, angles, spring lengths, normal reactions…), determining all of them requires at least distinct, non-trivial equations: a relation of the form does not count. When the two conditions are not enough, the third equation almost always comes from a geometric relation in the diagram: spring lengths that add up to a fixed distance, complementary angles, ropes running over pulleys. In many problems it is literally impossible to reach the solution without reading the geometry of the figure.
Links
Topics: Statics and equilibrium Concepts: Static equilibrium Objects: Spring
Related exercises: Worked Exercise — Block Hanging from Two Ropes · Worked Exercise — The Gorilla Pulls a Crate · Worked Exercise — Box with a Spring: Equilibrium Zone
Finora abbiamo trattato oggetti puntiformi, in cui tutte le forze si applicano nello stesso punto. Ma un’asse, una trave o una scala hanno un’estensione, e le forze agiscono su punti diversi: questo apre la possibilità che il corpo ruoti anche quando il suo centro resta fermo. Serve quindi un modello più ricco.
Principio — Corpo rigido
Un corpo rigido è un oggetto esteso (non puntiforme) in cui la distanza tra ogni coppia di punti è fissa e immutabile nel tempo. Esempi: una sbarra d’acciaio, un libro chiuso, un mattone. Controesempi: una fune, un elastico, un gas.
Per un corpo rigido in equilibrio statico non basta che la somma delle forze sia nulla. Immaginiamo di spingere il bordo destro di un libro verso l’alto e il bordo sinistro verso il basso con due forze uguali e opposte: la risultante è zero, il centro del libro non trasla, eppure il libro si mette a ruotare. Per impedirlo occorre annullare anche la tendenza a far girare il corpo, cioè la somma dei momenti delle forze.
Principio — Equilibrio di un corpo rigido
Un corpo rigido è in equilibrio statico se e solo se sono verificate entrambe le condizioni:
Il momento (detto anche momento torcente) di una forza rispetto a un polo misura la sua capacità di far ruotare il corpo attorno a quel polo, ed è
dove è la distanza dal polo alla retta su cui giace la forza, detta braccio. Il braccio non è la distanza dal punto di applicazione, ma dalla retta d’azione: una forza che punta dritto verso il polo ha braccio nullo e non fa ruotare nulla. Il segno è positivo se la forza tende a far ruotare in senso antiorario attorno al polo, negativo se in senso orario.
Scegli il polo furbamente
La seconda condizione vale rispetto a un polo qualsiasi: siamo liberi di scegliere quello che ci conviene. Un polo posto sul punto di applicazione di una forza ignota la elimina dall’equazione dei momenti, perché quella forza avrà braccio zero. Con una scelta accorta si può passare da tre incognite a una sola: la scelta del polo è libera ma decisiva per velocizzare i conti.
Il concetto di momento è centrale in gran parte della meccanica: lo ritroveremo e lo approfondiremo studiando il centro di massa dei corpi estesi e, più avanti, la dinamica delle rotazioni, dove i momenti governano non solo l’equilibrio ma anche il moto rotatorio vero e proprio.


Collegamenti
Argomenti: Statica ed equilibrio Concetti: Momento di una forza Competenze: Bilancio dei momenti · Scelta del polo Oggetti: Corpo rigido
Esercizi collegati: Esercizio svolto — Sistema con due masse e puleggia · Esercizio svolto — Giostra quadrata · Esercizio svolto — Scala appoggiata a un muro liscio
So far we have treated point-like objects, in which all forces are applied at the same point. But a rod, a beam or a ladder have an extent, and forces act on different points: this opens up the possibility that the body rotates even when its centre stays still. A richer model is therefore needed.
Principle — Rigid body
A rigid body is an extended (non point-like) object in which the distance between every pair of points is fixed and unchanging in time. Examples: a steel bar, a closed book, a brick. Counter-examples: a rope, an elastic band, a gas.
For a rigid body in static equilibrium it is not enough that the sum of the forces be zero. Imagine pushing the right edge of a book upward and the left edge downward with two equal and opposite forces: the resultant is zero, the centre of the book does not translate, and yet the book starts to rotate. To prevent this, the tendency to make the body spin must also be cancelled out, i.e. the sum of the moments of the forces.
Principle — Equilibrium of a rigid body
A rigid body is in static equilibrium if and only if both conditions are satisfied:
The moment (or torque) of a force about a pole measures its ability to rotate the body about that pole, and is
where is the distance from the pole to the line of action of the force, called the lever arm. The lever arm is not the distance from the point of application, but from the line of action: a force pointing straight at the pole has zero lever arm and causes no rotation at all. The sign is positive if the force tends to rotate anticlockwise about the pole, negative if clockwise.
Choose the pole wisely
The second condition holds about any pole: we are free to choose the one that suits us. A pole placed at the point of application of an unknown force removes it from the moment equation, because that force will have zero lever arm. With a shrewd choice one can go from three unknowns to just one: the choice of pole is free but decisive for speeding up the working.
The concept of moment is central to much of mechanics: we shall meet it again, and go further into it, when studying the centre of mass of extended bodies and, later, the dynamics of rotation, where moments govern not only equilibrium but genuine rotational motion.
Links
Topics: Statics and equilibrium Concepts: Moment of a force Skills: Torque balance · Choice of pole Objects: Rigid body
Related exercises: Worked Exercise — System with Two Masses and a Pulley · Worked Exercise — Square Roundabout · Worked exercise — Ladder leaning against a smooth wall
Una leva è un’asta rigida che può ruotare attorno a un punto fisso, il fulcro. Si usa per sollevare, tagliare o schiacciare applicando una forza diversa da quella che servirebbe ad agire direttamente sul carico. Il principio è quello già scritto per il corpo rigido: all’equilibrio la somma dei momenti rispetto al fulcro è nulla. Qui se ne fa il caso più semplice, con due forze perpendicolari all’asta, che è il caso delle forbici, dell’altalena e della carriola.
Si chiamano forza motrice la forza che applichiamo, e forza resistente la forza che il carico oppone, in modulo uguale al peso del carico quando lo si solleva piano, a velocità costante. I bracci e sono le distanze dal fulcro alle rette d’azione delle due forze, misurate perpendicolarmente a esse. Se le forze sono perpendicolari all’asta, il braccio coincide con la distanza dal fulcro al punto di applicazione. Il braccio non è «il pezzo di asta che si vede»: è la distanza fra il fulcro e la retta della forza, come nel bilancio dei momenti.
Equilibrio di una leva
Se le due forze sono perpendicolari all’asta e i loro momenti sono opposti, Il vantaggio meccanico è il rapporto Se si vince una forza resistente più grande della forza che si applica. L’asta non crea forza dal nulla: la mano percorre un arco più lungo del carico.
La condizione si legge in due versi. Noto il carico e i due bracci, la forza da applicare è . Nota la forza che sappiamo fare, il carico massimo è . Il peso dell’asta, in prima liceo, si trascura, oppure lo si pensa applicato nel centro e lo si aggiunge come un terzo momento. Qui lo trascuriamo, e lo diciamo.
Tre generi
Il genere dipende da dove sta il fulcro rispetto alle due forze. Non dipende da quale forza è più grande.
| Genere | Ordine lungo l’asta | Esempio | Vantaggio tipico |
|---|---|---|---|
| Primo | forza motrice, fulcro, forza resistente | altalena, forbici, piede di porco | può essere maggiore o minore di , secondo i bracci |
| Secondo | fulcro, forza resistente, forza motrice | carriola, schiaccianoci, apribottiglie | sempre maggiore di : |
| Terzo | fulcro, forza motrice, forza resistente | pinzette, pinza per il ghiaccio, avambraccio | sempre minore di : si applica più forza del carico, e si guadagna in spostamento |
Nel primo genere il fulcro sta in mezzo. L’altalena è il caso simmetrico: se i due bambini hanno lo stesso peso, stanno in equilibrio a distanze uguali dal perno. Se uno pesa il doppio, deve sedersi a metà distanza. Nelle forbici il fulcro è il perno: si fa meno fatica se si mette il materiale vicino al perno, perché il braccio resistente diventa corto e quello della mano resta lungo. Le cesoie da latta hanno il fulcro ancora più vicino alla lama.
Nel secondo genere il carico sta fra il fulcro e la mano. Nella carriola il fulcro è la ruota, il peso sta nel cassone e le mani stanno in fondo ai manici. Il braccio motore è più lungo del braccio resistente, quindi : si solleva un carico più pesante della forza applicata. Lo schiaccianoci funziona allo stesso modo. Il vantaggio è sempre maggiore di uno, perché la mano è l’estremo lontano e il carico è più vicino al fulcro.
Nel terzo genere la forza motrice sta fra il fulcro e il carico. Le pinzette si stringono nel mezzo e afferrano in punta: si fa più forza di quella che arriva sull’oggetto, e in cambio la punta si muove con precisione. L’avambraccio è una leva dello stesso genere. Il fulcro è il gomito, il bicipite si inserisce a pochi centimetri dal gomito, e il peso tenuto in mano sta a circa . Il muscolo tira più del peso che sostiene. Non è uno svantaggio gratuito: un accorciamento piccolo del bicipite sposta la mano di molto.
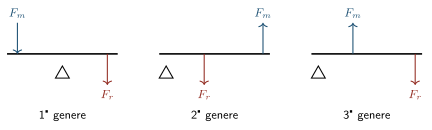
Il triangolo è il fulcro. Nel primo genere sta fra le due forze; nel secondo il carico sta in mezzo; nel terzo sta in mezzo la forza che applichiamo.
Esercizi svolti
Esercizio 1 — Altalena, primo genere
Un’altalena ha il perno al centro. Anna, di massa , siede a dal perno. Dove deve sedere suo fratello, di massa , perché l’altalena resti in equilibrio orizzontale? Si prenda e si trascuri la massa dell’asse.
I pesi sono e . All’equilibrio i momenti rispetto al perno sono uguali. Il fattore compare da entrambe le parti e si semplifica, quindi basta uguagliare e : Il fratello siede a dal perno, dalla parte opposta. Il risultato è esatto; le masse hanno due cifre e ne ha due, e ne ha due. Controllo dei momenti: e , a tre cifre del prodotto. Sono uguali.
Esercizio 2 — Carriola, secondo genere
Una carriola porta un sacco di cemento di massa . Il baricentro del sacco dista dall’asse della ruota, che è il fulcro. Le mani impugnano i manici a dalla ruota. Che forza verticale devono applicare le mani per tenere la carriola in equilibrio, a manici orizzontali? Si trascuri il peso della carriola vuota e si prenda .
È una leva di secondo genere: fulcro (ruota), poi carico, poi mani. Il peso del sacco è I bracci sono e . Dalla condizione di equilibrio I dati , e hanno due cifre significative, quindi Il vantaggio meccanico è : le mani fanno un terzo del peso. sono circa il peso di una massa di , una forza ragionevole per sollevare di cemento con una carriola. Se il sacco fosse sulla verticale della ruota, il braccio resistente sarebbe nullo e le mani non farebbero forza: il carico graverebbe tutto sull’asse.
Esercizio 3 — Avambraccio, terzo genere
Si schematizza l’avambraccio come un’asta orizzontale, fulcro nel gomito. Il bicipite si inserisce a dal gomito e tira verso l’alto. La mano regge un pallone da a dal gomito. Qual è la forza del bicipite, se si trascura il peso dell’avambraccio? .
È una leva di terzo genere: la forza motrice sta fra il fulcro e il carico, e . Il peso del pallone è La forza del bicipite è A due cifre significative, come e , Il muscolo tira circa otto volte il peso del pallone. Il vantaggio meccanico è , che a due cifre significative si scrive . È minore di uno: si spende forza, e si guadagna spostamento. Un accorciamento di del bicipite, con questi bracci, sposta la mano di . Il peso dell’avambraccio, trascurato qui, aggiungerebbe un momento e alzerebbe ancora .
Errori tipici
- Scambiare i bracci nel rapporto. , non il contrario. La forza più lontana dal fulcro è la più piccola. Se il conto dice che per sollevare con un piede di porco un sasso di (circa di peso) servono , i bracci sono finiti al posto sbagliato: con il fulcro vicino al sasso la forza della mano deve essere minore del peso, non maggiore.
- Misurare il braccio lungo la traiettoria della mano. Il braccio è la distanza dal fulcro alla retta della forza, non l’arco percorso. L’arco entra nel discorso sullo spostamento, non nell’equilibrio.
- Dimenticare che le forze devono essere quelle perpendicolari all’asta. Se si tira di sbieco, il braccio non è la distanza lungo l’asta. In questi esercizi le forze sono verticali e l’asta orizzontale, quindi il braccio è la distanza dal fulcro.
- Classificare la leva dalla forza più grande, invece che dall’ordine. Il genere si legge sulla posizione del fulcro. Una leva di terzo genere può essere faticosa e restare di terzo genere.
- Contare il peso dell’asta due volte, o non dire che lo si trascura. Se l’asta è pesante, il suo peso è un’altra forza, applicata nel baricentro, con il suo braccio. O lo si mette nell’equazione dei momenti, o si scrive che l’asta si considera leggera.
Collegamenti
Argomenti: Statica ed equilibrio Concetti: Leve · Equilibrio statico · Momento di una forza Competenze: Bilancio dei momenti
Vedi anche: Corpo rigido ed equilibrio rotazionale · Equilibrio del corpo rigido · Altalena e fulcro
A lever is a rigid bar that can rotate about a fixed point, the fulcrum. It is used to lift, cut or crush by applying a force different from the one that would be needed to act directly on the load. The principle is the one already written for the rigid body: at equilibrium the sum of the moments about the fulcrum is zero. Here we take the simplest case, with two forces perpendicular to the bar, which is the case of scissors, a seesaw and a wheelbarrow.
The effort is the force we apply, and the load is the force the burden opposes, in magnitude equal to the weight of the burden when it is lifted slowly, at constant velocity. The arms and are the distances from the fulcrum to the lines of action of the two forces, measured perpendicular to them. If the forces are perpendicular to the bar, the arm coincides with the distance from the fulcrum to the point of application. The arm is not “the piece of bar one sees”: it is the distance between the fulcrum and the line of the force, as in the balance of moments.
Equilibrium of a lever
If the two forces are perpendicular to the bar and their moments are opposite, The mechanical advantage is the ratio If one overcomes a load larger than the force one applies. The bar does not create force from nothing: the hand travels along a longer arc than the load.
The condition is read in two directions. Given the load and the two arms, the force to apply is . Given the force one can exert, the maximum load is . The weight of the bar, in the first year, is neglected, or it is thought of as applied at the centre and added as a third moment. Here we neglect it, and we say so.
Three classes
The class depends on where the fulcrum sits relative to the two forces. It does not depend on which force is larger.
| Class | Order along the bar | Example | Typical advantage |
|---|---|---|---|
| First | effort, fulcrum, load | seesaw, scissors, crowbar | can be greater or less than , depending on the arms |
| Second | fulcrum, load, effort | wheelbarrow, nutcracker, bottle opener | always greater than : |
| Third | fulcrum, effort, load | tweezers, ice tongs, forearm | always less than : one applies more force than the load, and gains displacement |
In the first class the fulcrum is in the middle. The seesaw is the symmetric case: if the two children have the same weight, they balance at equal distances from the pivot. If one weighs twice as much, that child must sit at half the distance. In scissors the fulcrum is the pivot: cutting takes less effort if the material is placed close to the pivot, because the load arm becomes short while the arm of the hand stays long. Tin snips have the fulcrum even closer to the blade.
In the second class the load sits between the fulcrum and the hand. In a wheelbarrow the fulcrum is the wheel, the weight sits in the bin and the hands sit at the end of the handles. The effort arm is longer than the load arm, so : one lifts a burden heavier than the applied force. A nutcracker works in the same way. The advantage is always greater than one, because the hand is the far end and the load is closer to the fulcrum.
In the third class the effort sits between the fulcrum and the load. Tweezers are squeezed in the middle and grip at the tip: one exerts more force than arrives on the object, and in return the tip moves with precision. The forearm is a lever of the same class. The fulcrum is the elbow, the biceps inserts a few centimetres from the elbow, and the weight held in the hand sits about away. The muscle pulls more than the weight it supports. It is not a free disadvantage: a small shortening of the biceps moves the hand a long way.
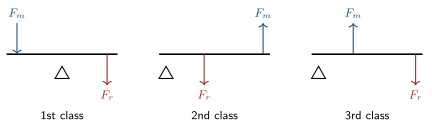
The triangle is the fulcrum. In the first class it sits between the two forces; in the second the load is in the middle; in the third the force we apply is in the middle.
Worked exercises
Exercise 1 — Seesaw, first class
A seesaw has its pivot at the centre. Anna, of mass , sits from the pivot. Where must her brother, of mass , sit so that the seesaw stays horizontal in equilibrium? Take and neglect the mass of the beam.
The weights are and . At equilibrium the moments about the pivot are equal. The factor appears on both sides and cancels, so it is enough to set equal to : The brother sits from the pivot, on the opposite side. The result is exact; the masses have two figures and has two, and has two. Check of the moments: and , to three figures of the product. They are equal.
Exercise 2 — Wheelbarrow, second class
A wheelbarrow carries a bag of cement of mass . The centre of mass of the bag is from the axle of the wheel, which is the fulcrum. The hands grip the handles from the wheel. What vertical force must the hands apply to hold the wheelbarrow in equilibrium, with the handles horizontal? Neglect the weight of the empty wheelbarrow and take .
It is a second-class lever: fulcrum (wheel), then load, then hands. The weight of the bag is The arms are and . From the equilibrium condition The data , and have two significant figures, so The mechanical advantage is : the hands exert one third of the weight. is about the weight of a mass of , a reasonable force for lifting of cement with a wheelbarrow. If the bag were on the vertical through the wheel, the load arm would be zero and the hands would exert no force: the burden would bear entirely on the axle.
Exercise 3 — Forearm, third class
The forearm is modelled as a horizontal bar, with the fulcrum at the elbow. The biceps inserts at from the elbow and pulls upwards. The hand holds a ball of at from the elbow. What is the force of the biceps, if the weight of the forearm is neglected? .
It is a third-class lever: the effort sits between the fulcrum and the load, and . The weight of the ball is The force of the biceps is To two significant figures, as in and , The muscle pulls about eight times the weight of the ball. The mechanical advantage is , which to two significant figures is written . It is less than one: one spends force, and gains displacement. A shortening of of the biceps, with these arms, moves the hand by . The weight of the forearm, neglected here, would add a moment and raise further.
Typical mistakes
- Swapping the arms in the ratio. , not the reverse. The force farther from the fulcrum is the smaller one. If the calculation says that lifting a rock (a weight of about ) with a crowbar takes , the arms have ended up in the wrong places: with the fulcrum close to the rock, the force of the hand must be smaller than the weight, not larger.
- Measuring the arm along the path of the hand. The arm is the distance from the fulcrum to the line of the force, not the arc travelled. The arc enters the discussion of displacement, not of equilibrium.
- Forgetting that the forces must be the ones perpendicular to the bar. If one pulls at a slant, the arm is not the distance along the bar. In these exercises the forces are vertical and the bar is horizontal, so the arm is the distance from the fulcrum.
- Classifying the lever by the larger force, instead of by the order. The class is read from the position of the fulcrum. A third-class lever can be tiring and still be third class.
- Counting the weight of the bar twice, or not saying that it is neglected. If the bar is heavy, its weight is another force, applied at the centre of mass, with its own arm. Either one puts it in the moment equation, or one writes that the bar is taken to be light.
Links
Topics: Statics and equilibrium Concepts: Levers · Static equilibrium · Moment of a force Skills: Balance of moments
See also: Rigid body and rotational equilibrium · Equilibrium of a rigid body · Seesaw and fulcrum